
Meet Swachh
Rover AI
An intelligent autonomous rover designed to detect, navigate and manage waste in real-world environments — combining robotics, computer vision and AI decision-making.

Waste Management Needs Intelligence
Traditional waste collection often depends heavily on manual inspection, fixed collection schedules and limited visibility into waste conditions. Swachh Rover AI aims to introduce robotics and artificial intelligence into this process.
Manual Collection
Traditional waste collection depends heavily on manual inspection and physical effort, limiting efficiency and scalability in large or complex environments.
Poor Waste Visibility
Waste type and exact location are often unknown before collection begins. Fixed schedules mean waste may accumulate between visits.
Difficult Environments
Uneven surfaces, narrow corridors and obstacles make conventional collection systems less flexible and harder to operate consistently.
One Rover. Multiple Capabilities.
Swachh Rover AI combines robotics, computer vision, intelligent decision-making and autonomous mobility into one integrated platform.
Camera and sensors identify waste objects and classify them by type using AI computer vision.
Built to Move
Click the hotspots to explore key hardware components of Swachh Rover AI.
Select any highlighted point on the rover image to learn about that component.
The Rover Can See.
AI-powered object detection identifies and classifies waste in real time. Demo simulation — not connected to live model.
How the AI Works
From camera input to physical rover action — the complete AI processing pipeline.
Smart Classification
Powered by Technology
Technologies driving Swachh Rover AI — distinguishing current prototype capabilities from future development.
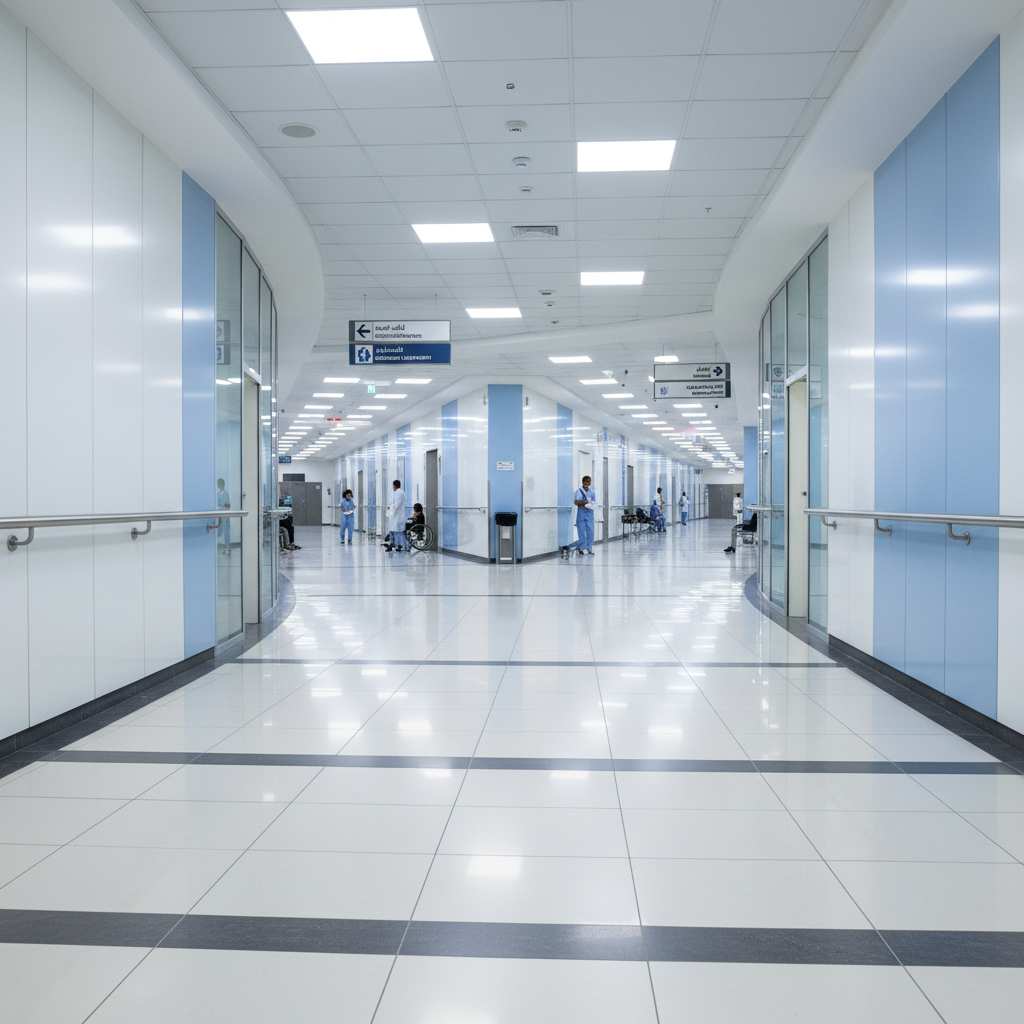
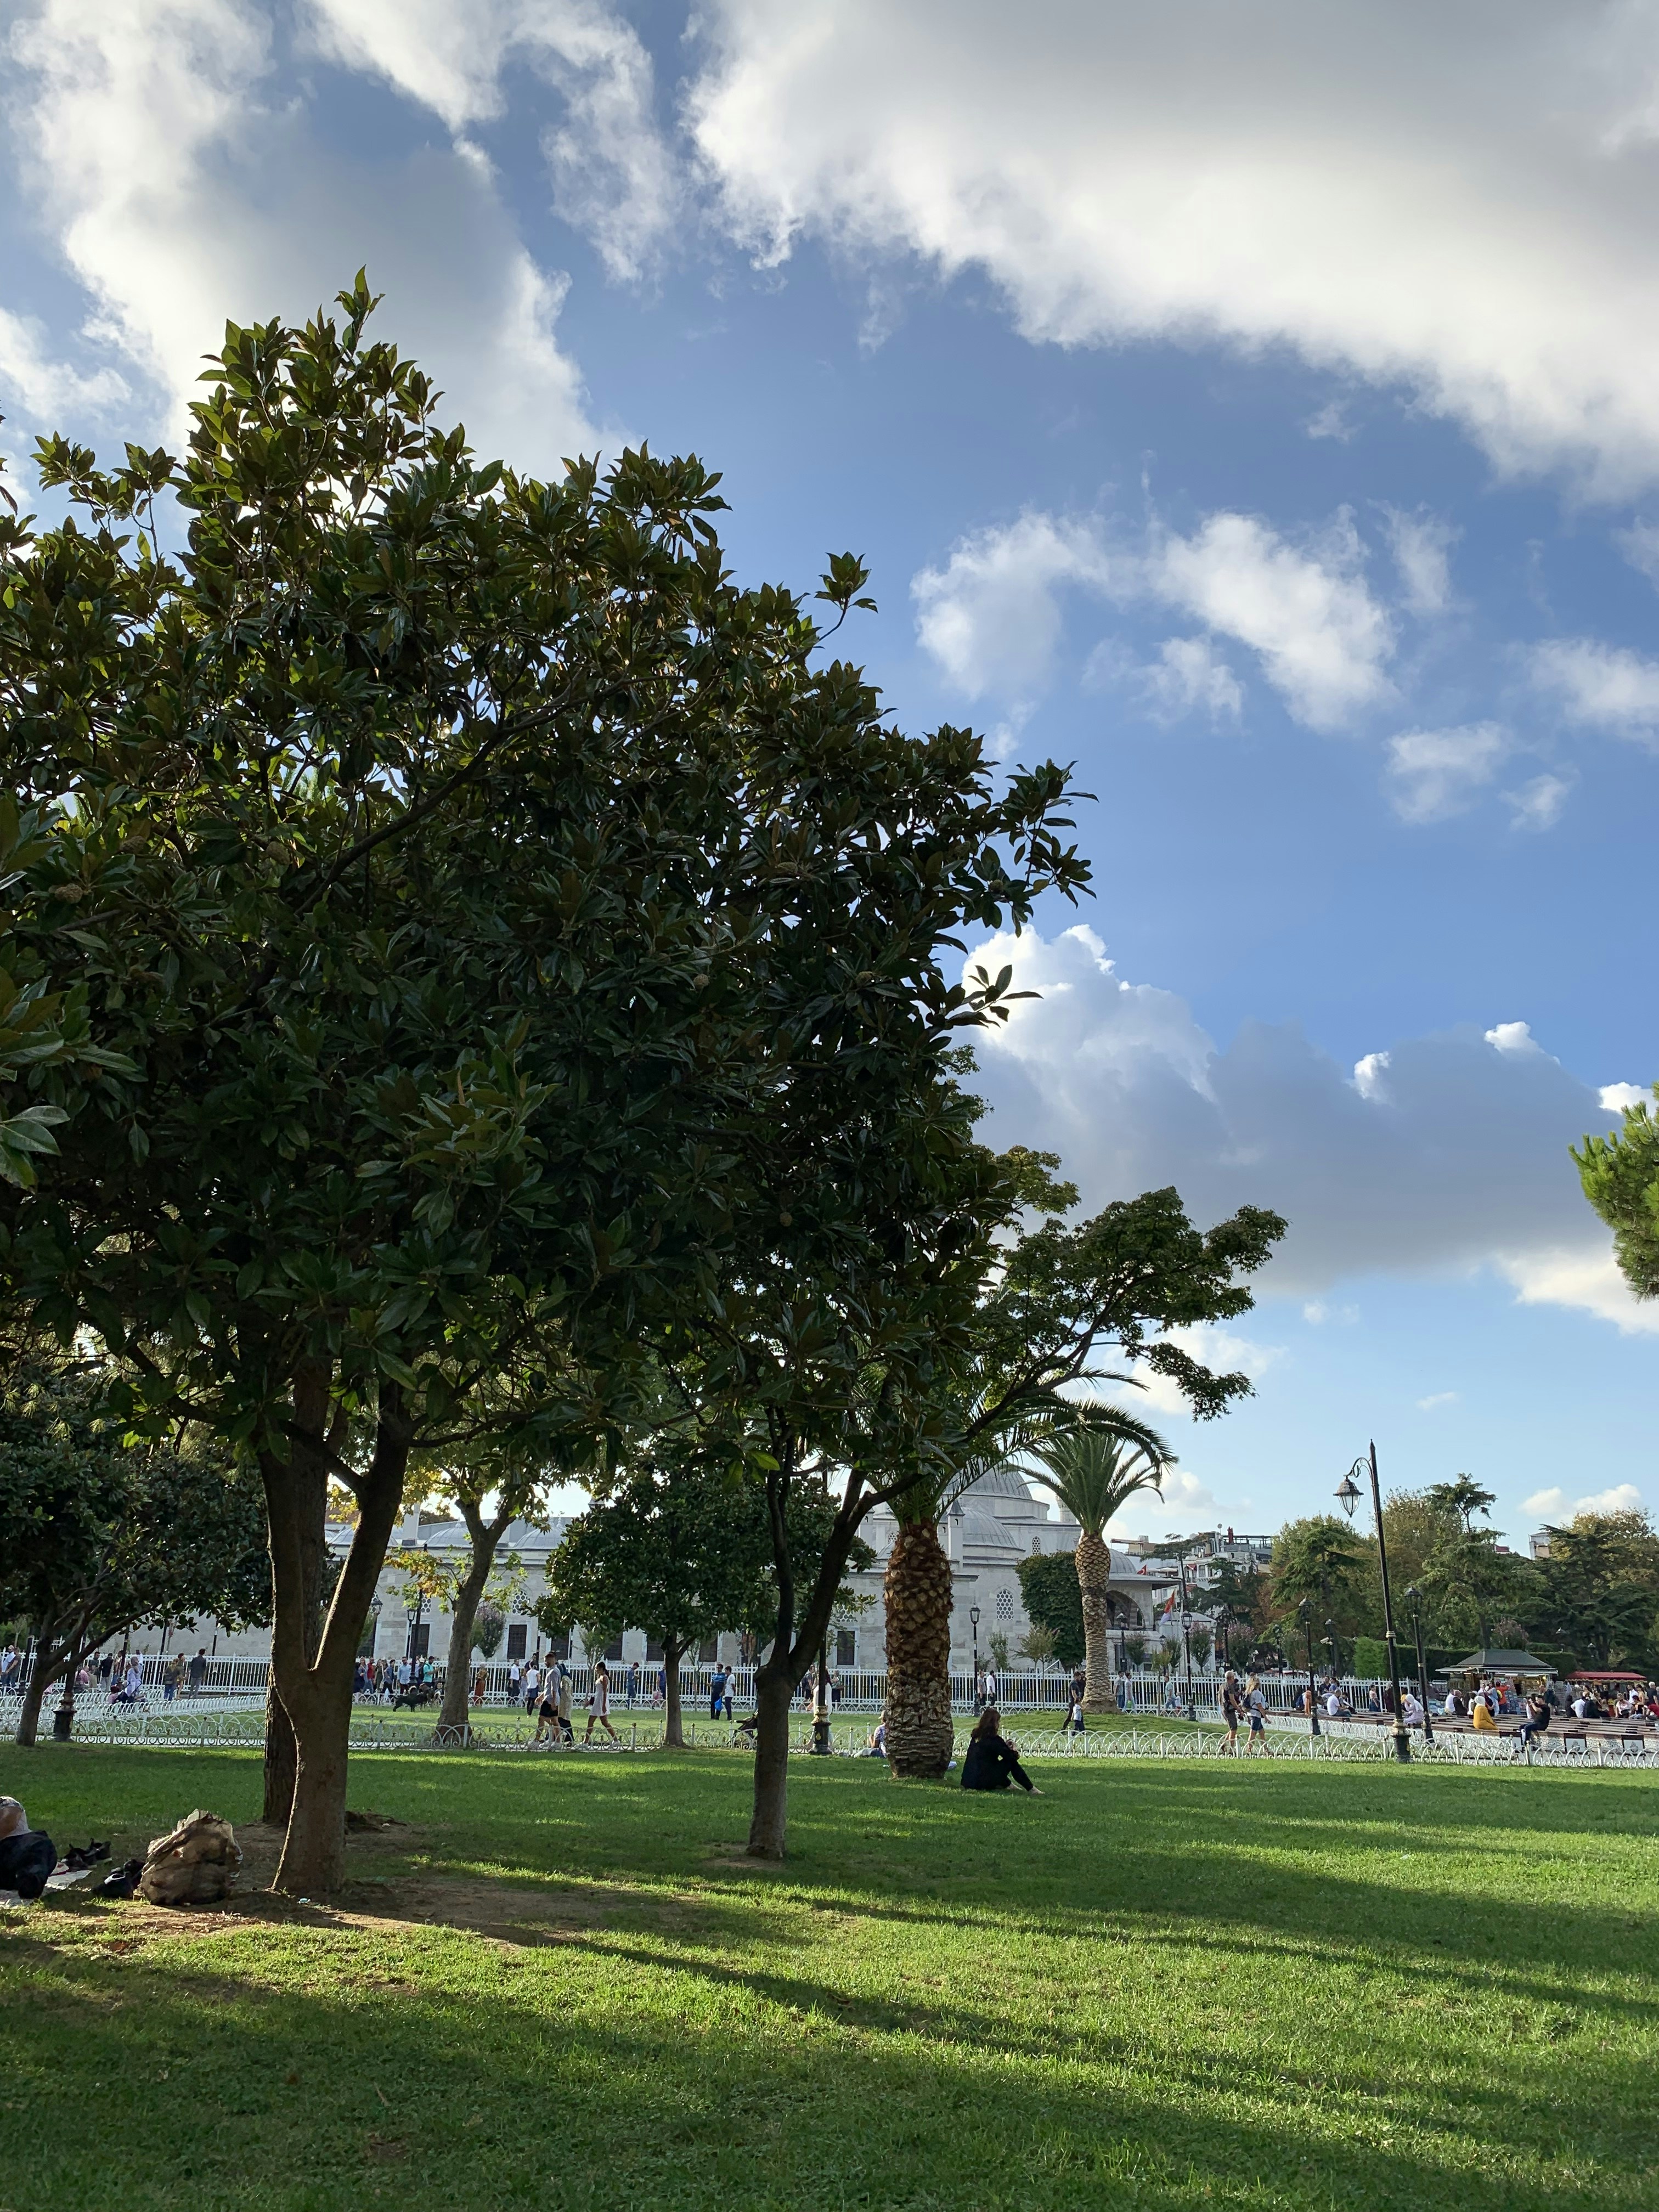
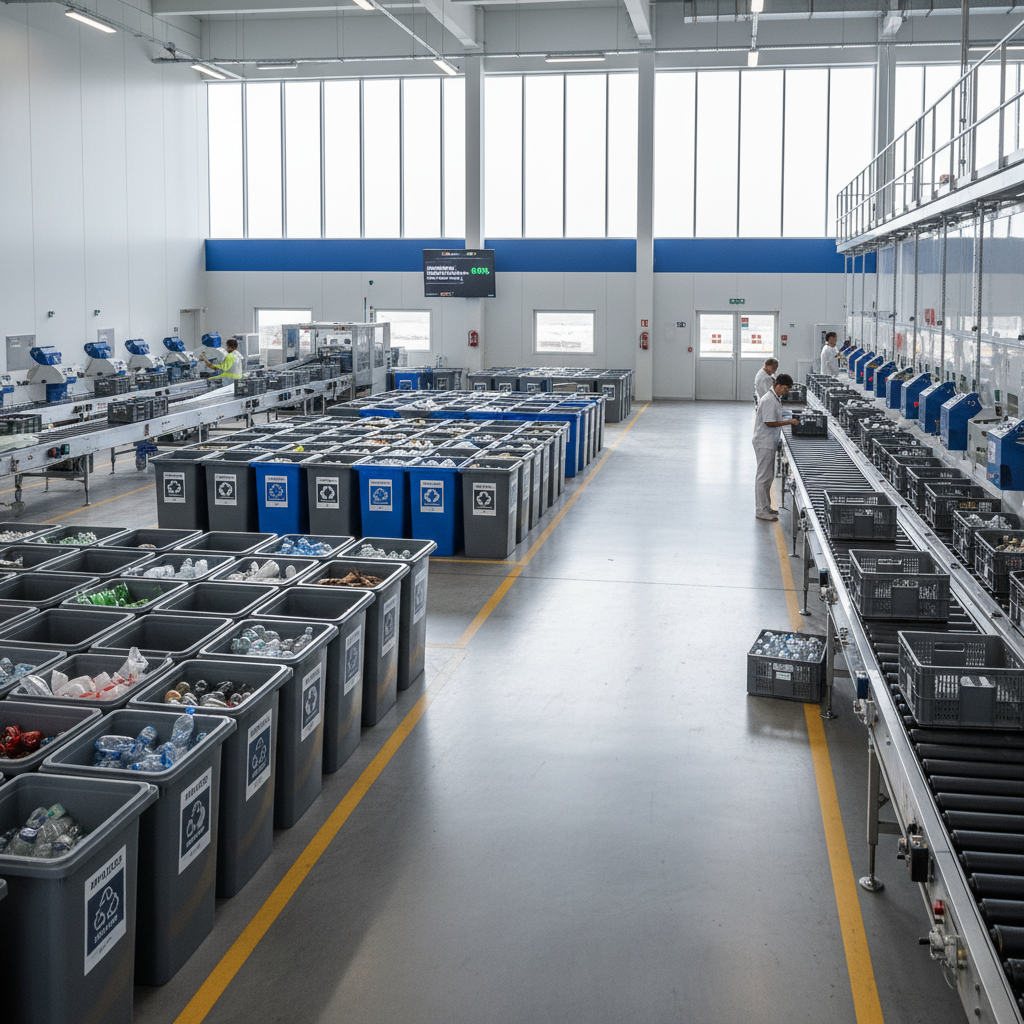
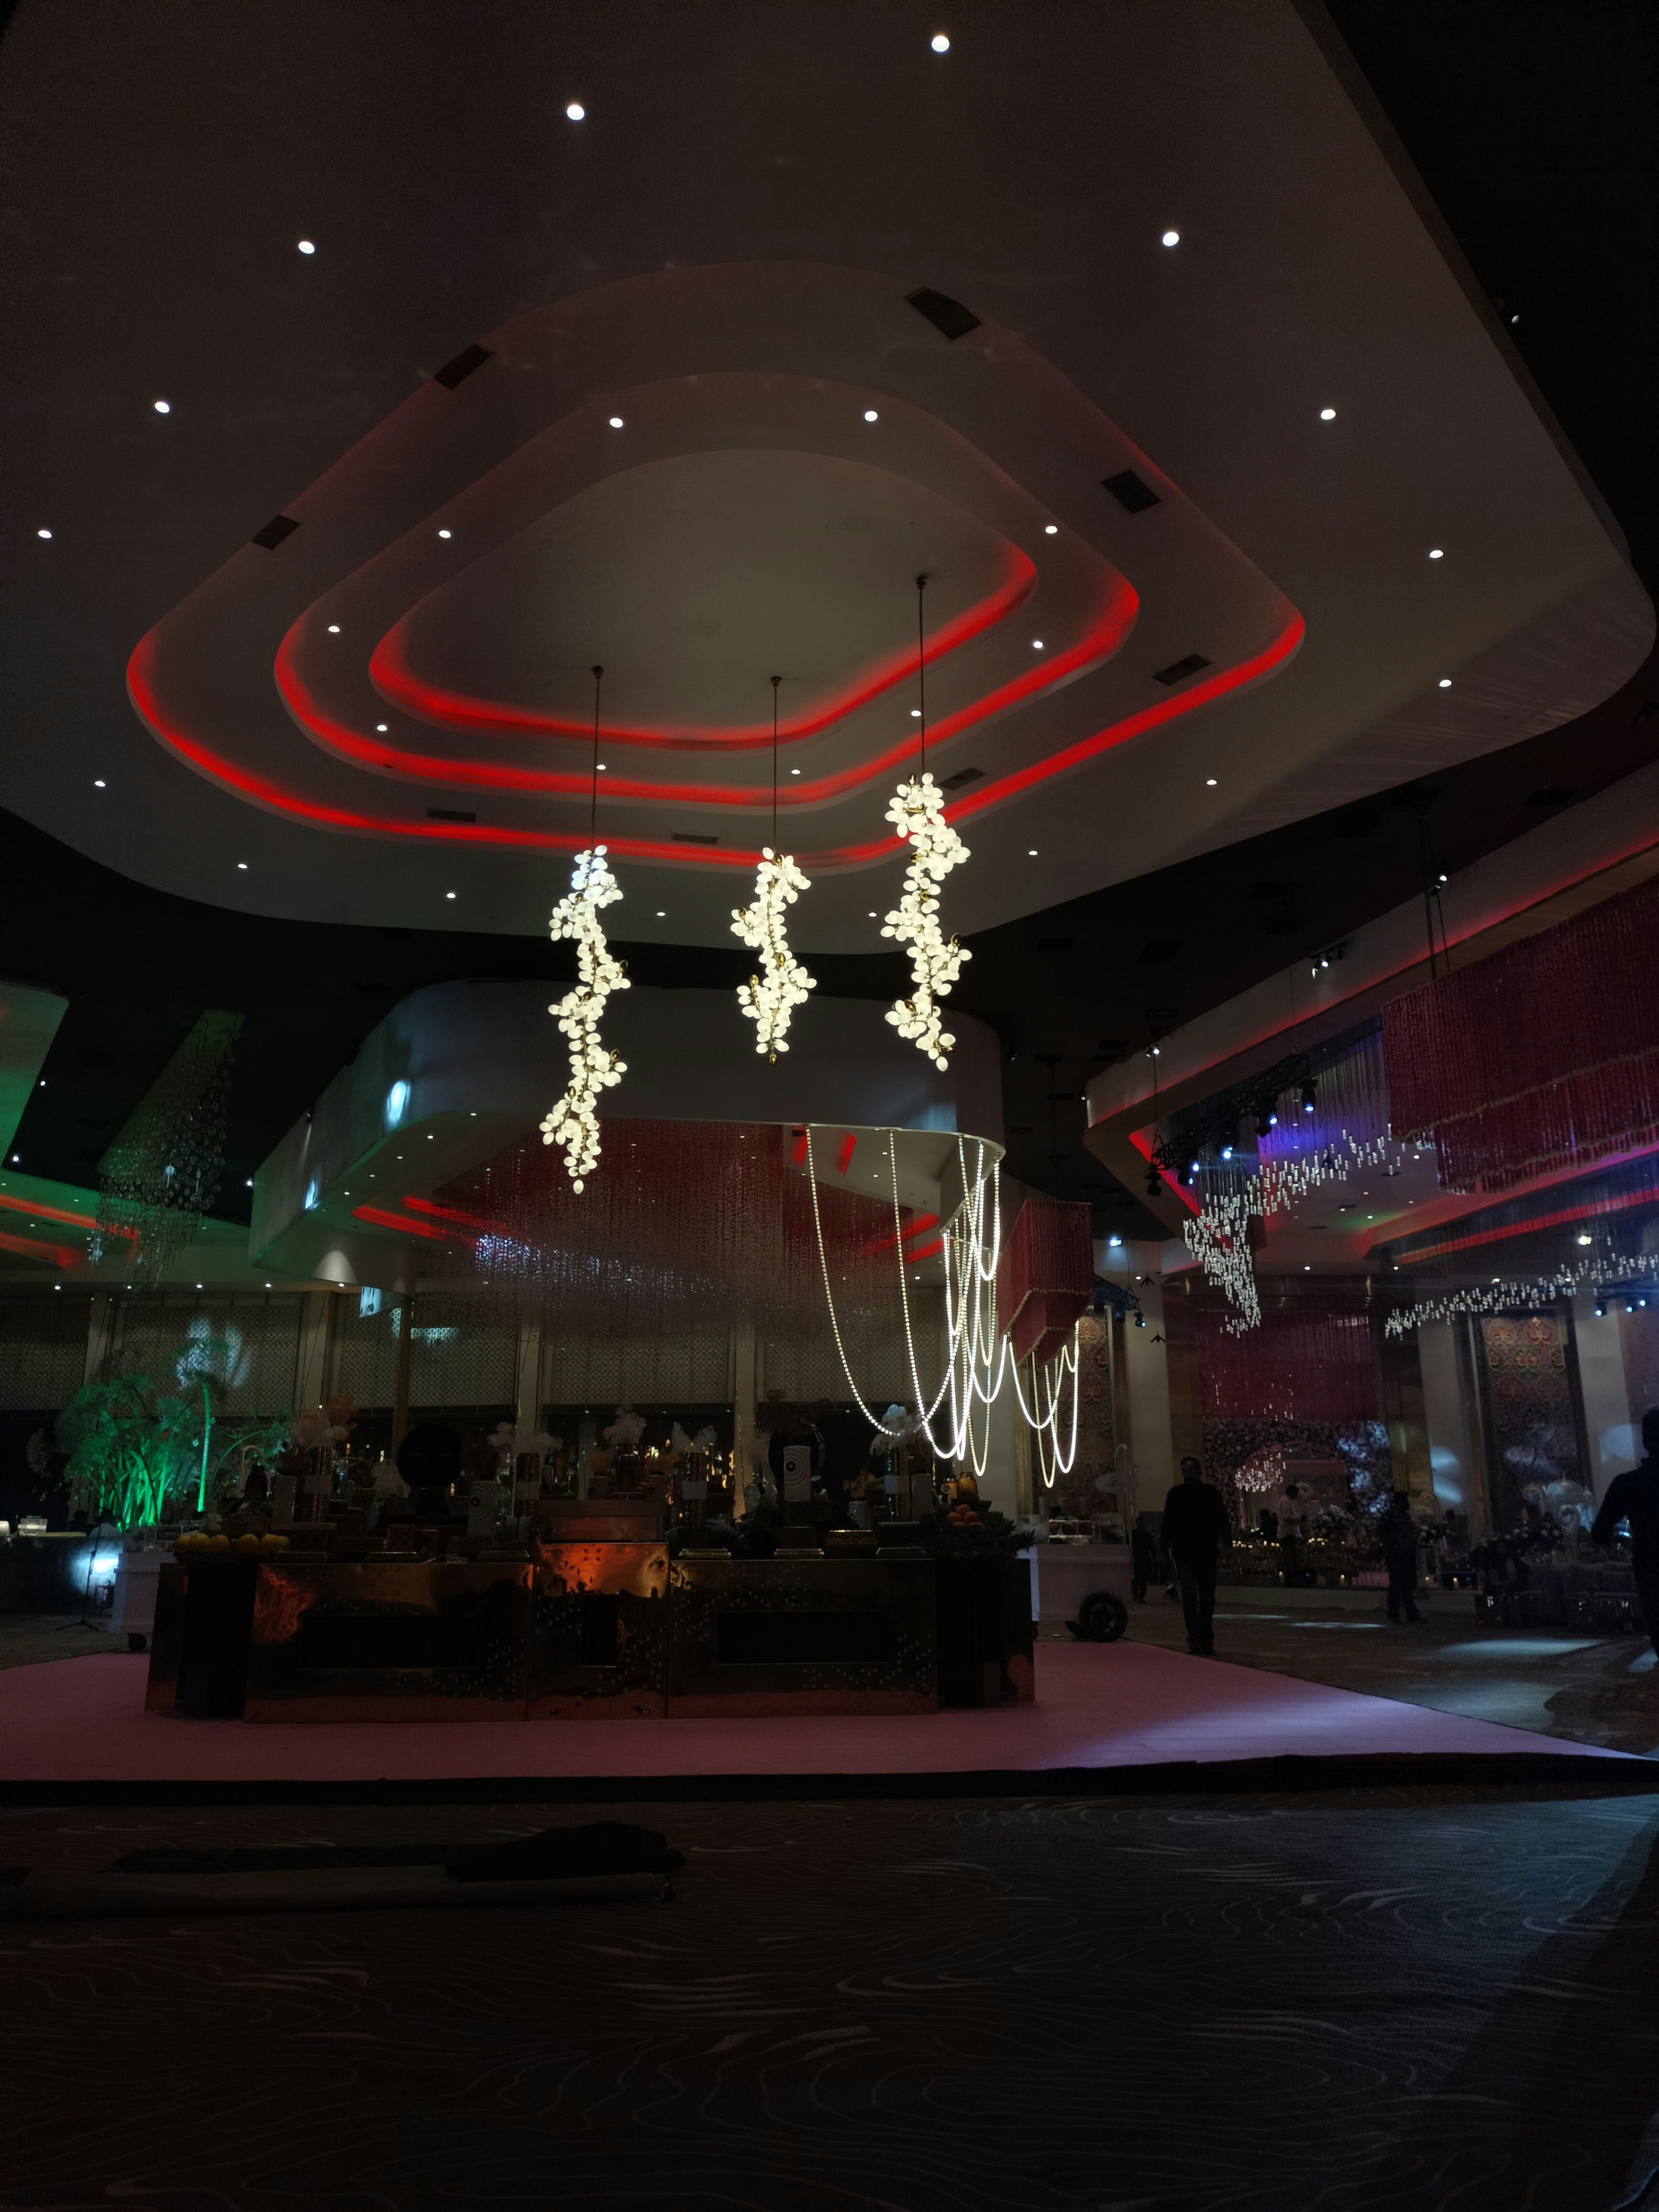
Where Swachh Rover AI Can Work
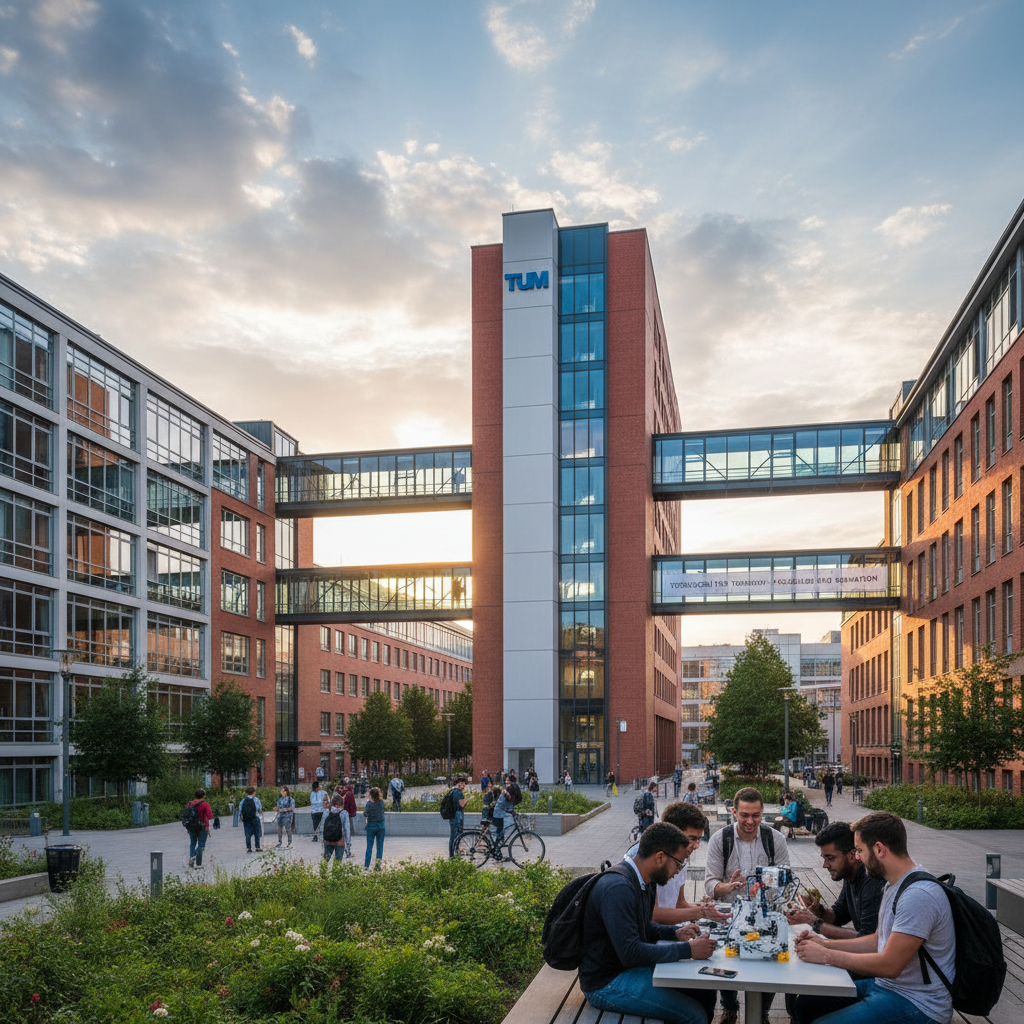
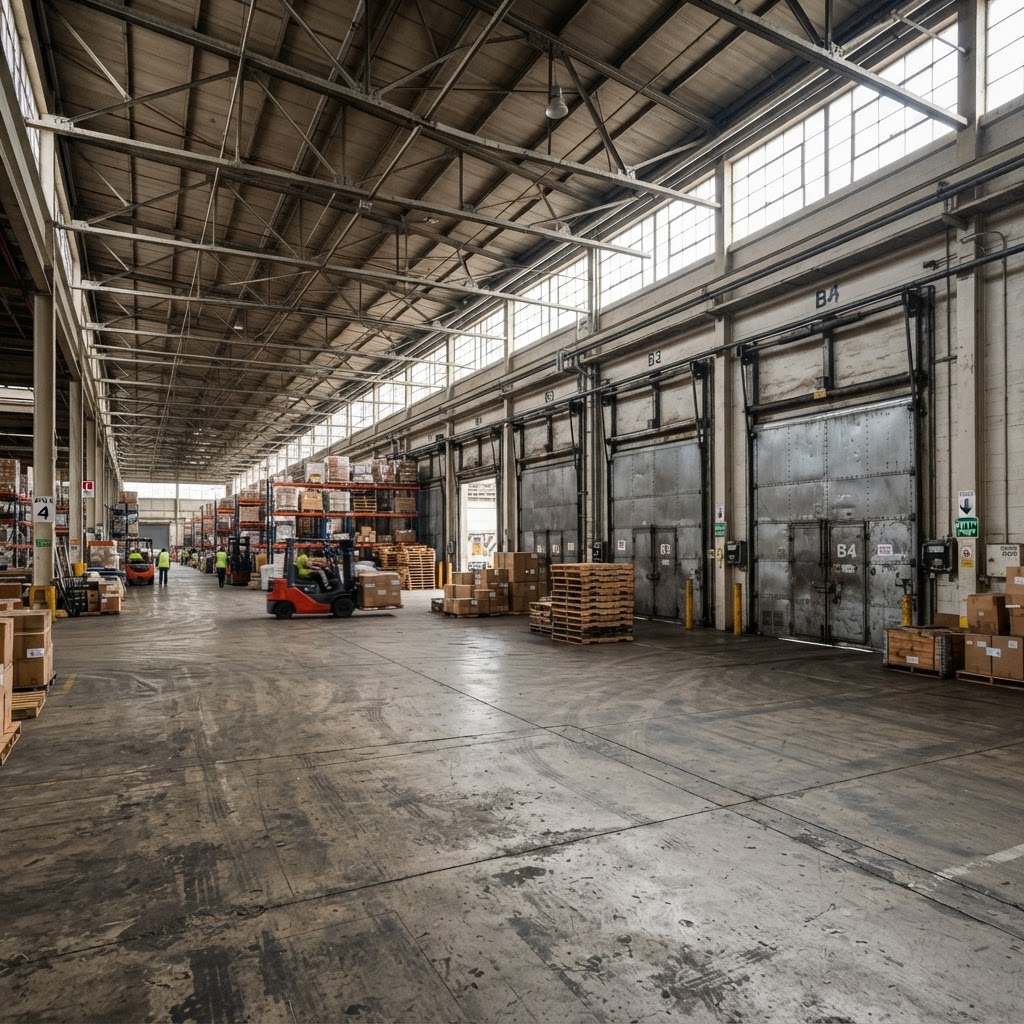
From Prototype to Autonomous Platform
Obstacle avoidance and path planning in structured environments.
Designed to Make a Difference
Cleaner Spaces
Automated detection and collection for consistently cleaner environments.
Less Manual Effort
Reduce physical burden on waste management personnel.
Smarter Decisions
AI-driven waste classification and prioritized collection routing.
Autonomous Ops
Continuous operation without constant human supervision.
Sustainable Tech
Energy-efficient robotics supporting environmental goals.
Data Insights
Waste pattern analytics to optimize collection schedules.
Project Gallery
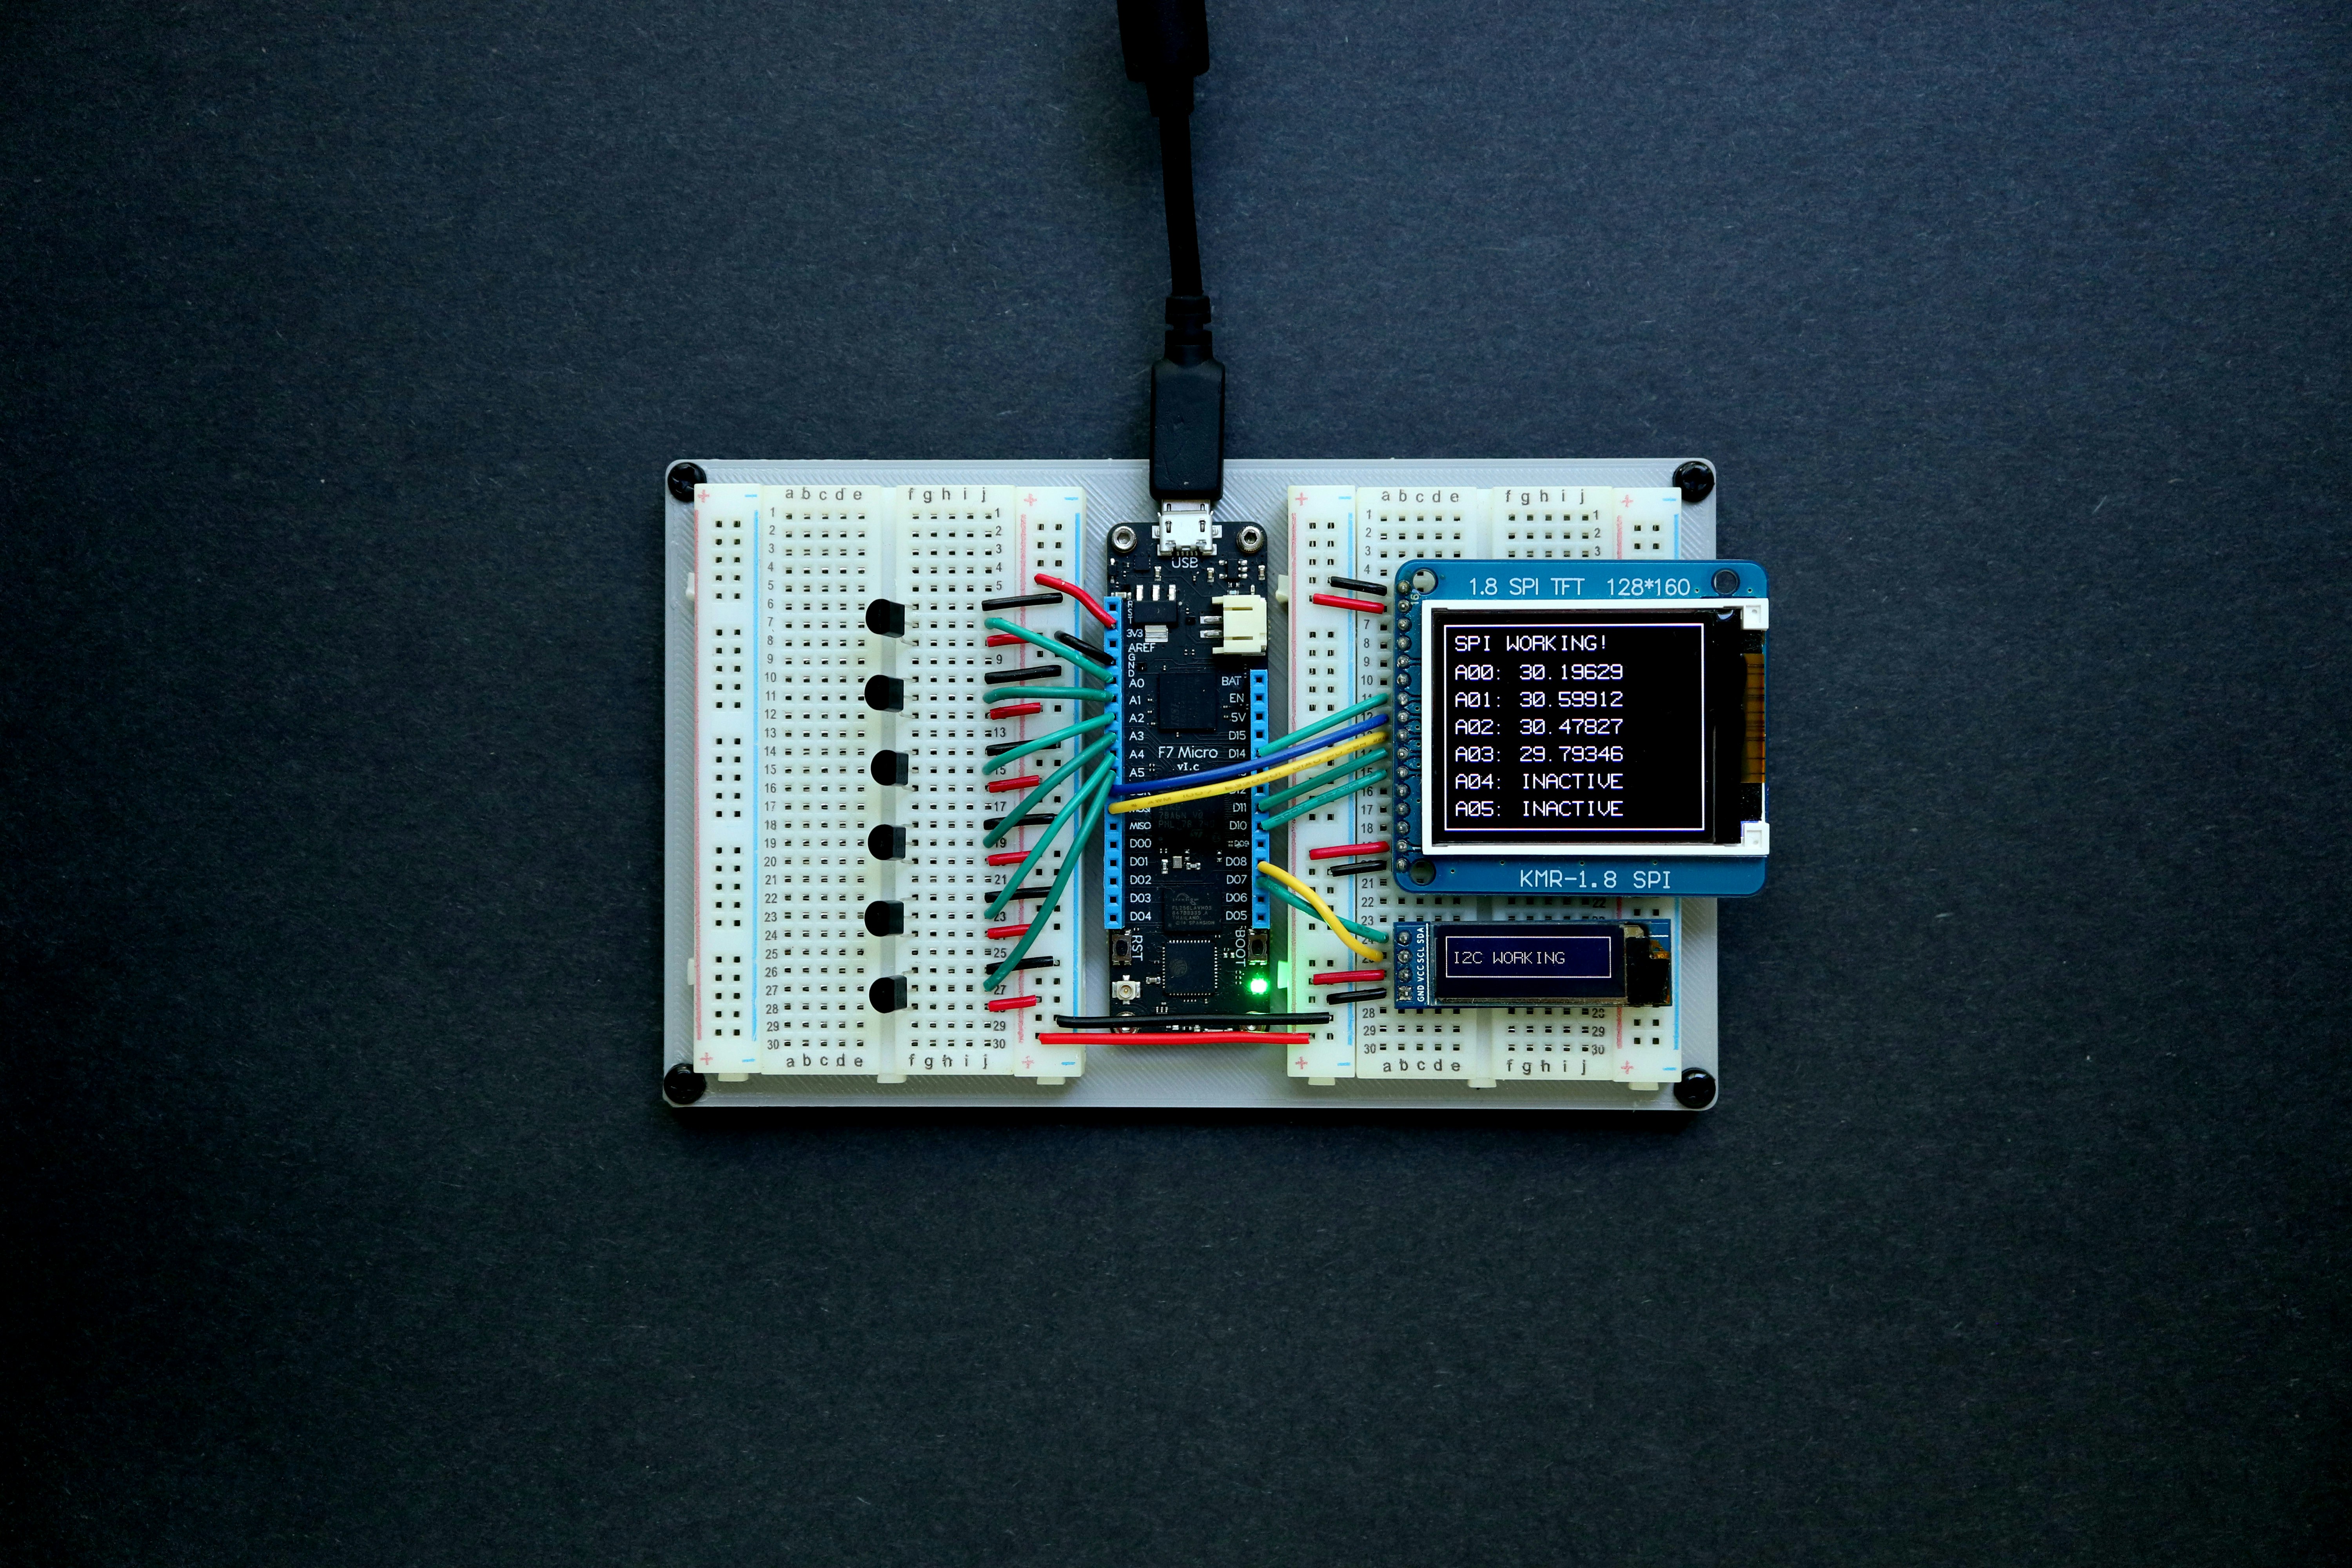
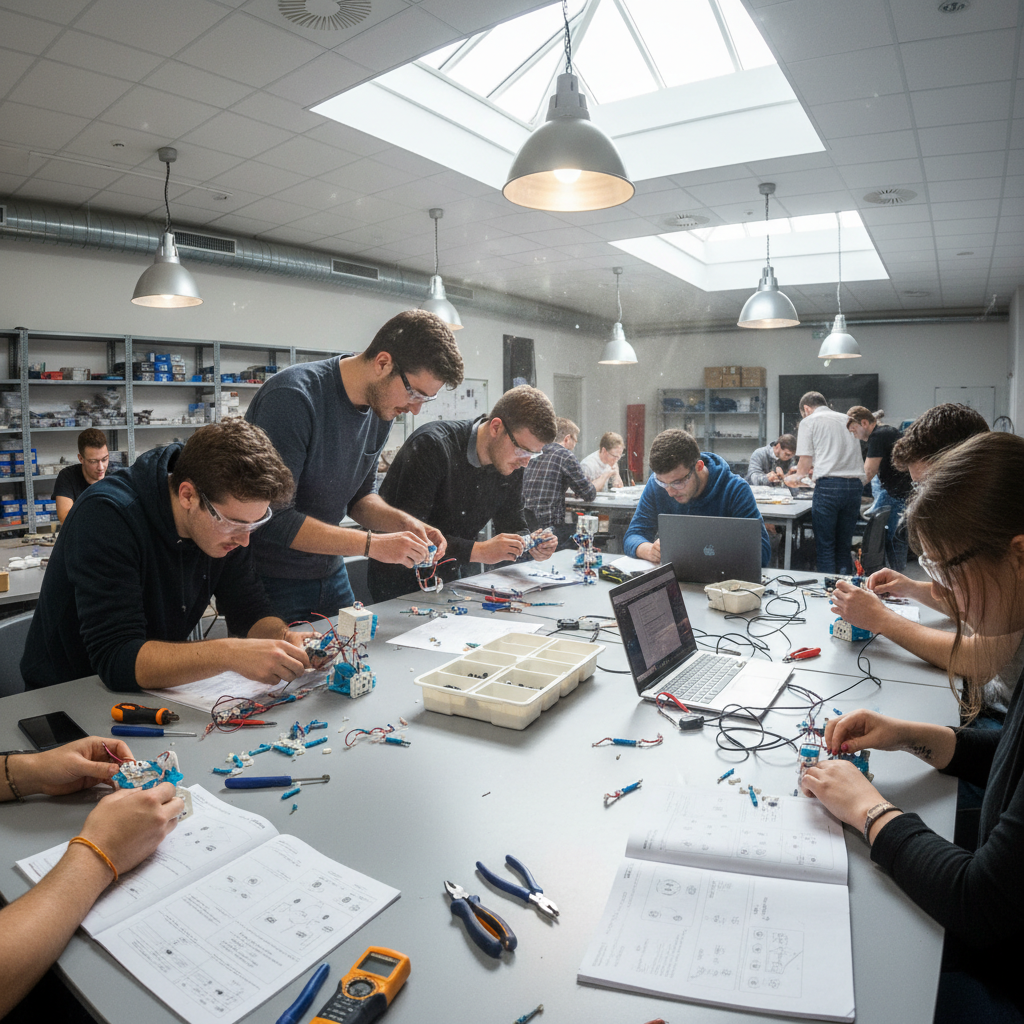
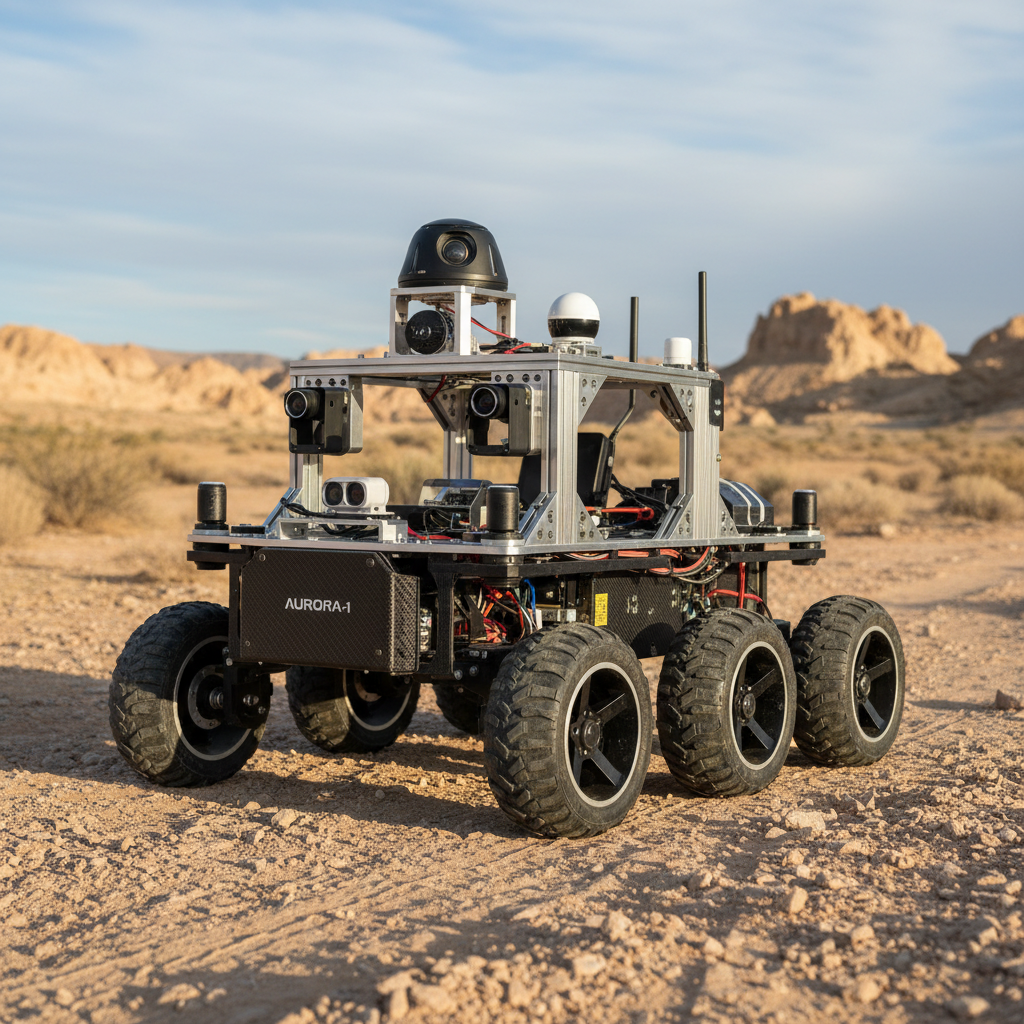
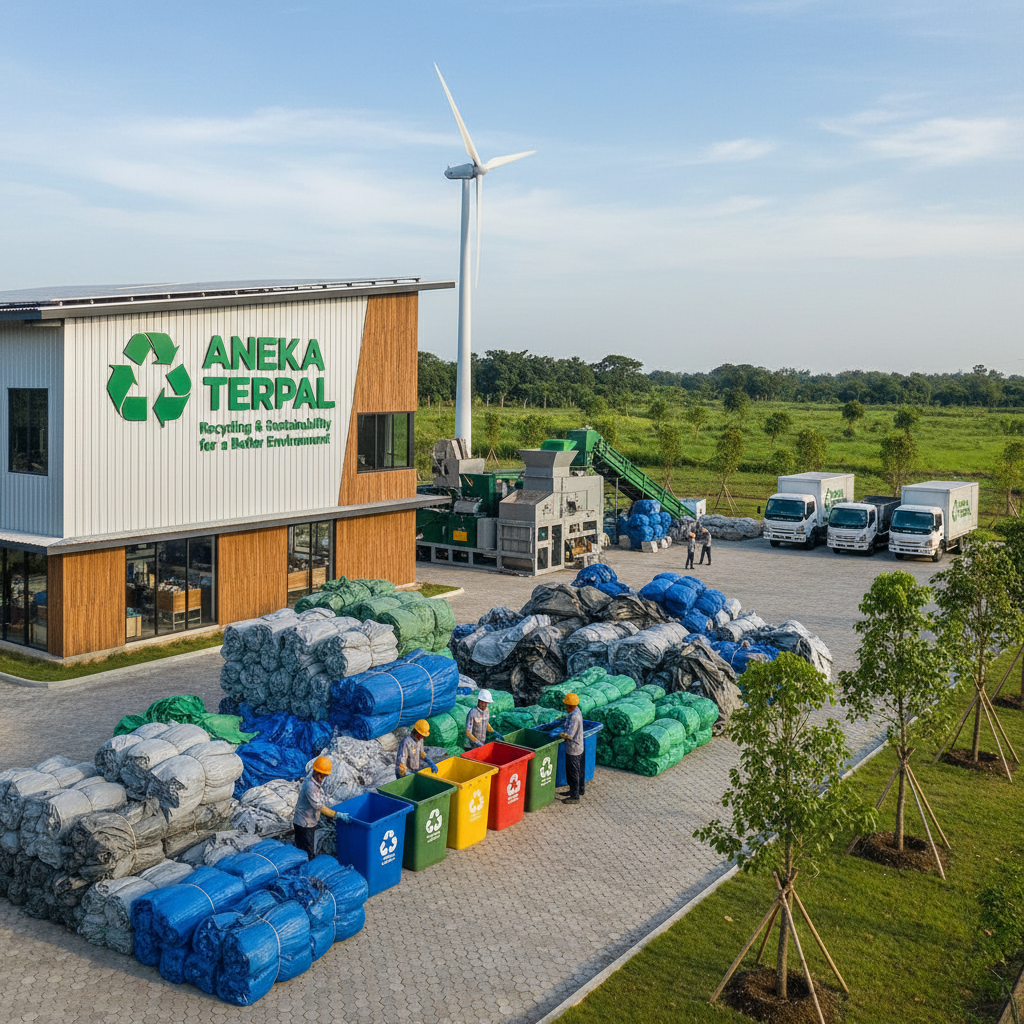
From Concept to Working Prototype
Swachh Rover AI evolved through a structured engineering process — from initial idea to a functional AI-powered rover prototype.
Conceived the problem of manual waste collection and explored robotics as a solution.
Mechanical design of the 6WD chassis, wheel placement and structural layout.
Physical construction of the rover frame using metal and aluminium components.
Integration of DC motors, microcontroller, wiring and power systems.
Firmware development for motor control, sensor reading and basic navigation.
Training and integration of computer vision model for waste detection and classification.
Field testing on varied terrain, tuning detection thresholds and navigation logic.
Preparing for real-world environment trials and iterative improvement.
The People Behind Swachh Rover
Software and hardware working together to build an intelligent autonomous waste-management rover.

Ayush Gupta
Founder & Team Lead — Swachh Rover AI
Leading the development of Swachh Rover AI with a focus on robotics, artificial intelligence, computer vision and autonomous systems.
Our Team
A multidisciplinary team combining software, artificial intelligence, robotics and hardware.

Software
Hardware
Software Team
Intelligence, vision & autonomous control
Artificial Intelligence
AI-powered decision making
Computer Vision
Intelligent waste detection
Autonomous Systems
Navigation & control
Software & Dashboard
Control, monitoring & analytics
Hardware Team
Robotics, electronics & rover mobility
Robotics
Autonomous rover systems
Rover Chassis
Strong mechanical structure
Motors & Drive
6-wheel all-terrain mobility
Sensors & Electronics
Embedded hardware systems
The Future of Waste Management Is Autonomous.
Building smarter, cleaner and more intelligent environments with robotics and AI. Join us in developing the next generation of autonomous waste management technology.
Get in Touch
Interested in collaborating, learning more about Swachh Rover AI, or exploring partnership opportunities? Reach out below.